New tools for the analysis of massive geolocated datasets (e.g., Bayesian inference and particle filtering) to ensure the reliability
of new mobility solutions (SHM for Vehicles and Infrastructure).
Improving the Efficiency and Resilience of Infrastructure
Efficient Transportation and Safe Mobility
This research theme aims to investigate and develop new model-based and model-free approaches for processing massive datasets collected
from different types of objects (structures, vehicles, etc.). It includes research activities carried out within our joint I4S research
team with Inria.
Develop robust statistical algorithms that are resilient to noise and environmental variations, and assess the impact of uncertainties.
Study and develop new approaches combining physical models with statistical methods.
Study and develop new methods for monitoring transient systems under highly variable operating conditions.
Algorithmic Optimization and Robustness for HPC Deployment (e.g., GPGPU).
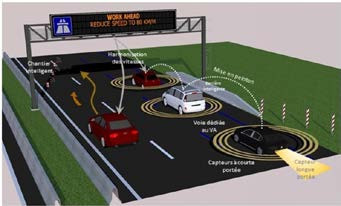
Instrumentation systems required for Autonomous Vehicle guidance: trajectory metrology, measurement synchronization, and redundancy of
satellite-based geolocation and vision systems.
Lane-level positioning and map matching using enriched maps.
Five challenges will be addressed:
Damage Localization
�Monitoring and Mitigation of Thermal Effects
Remote SHM of Large Structures, Including Offshore Wind Turbines (Full-Field and Contactless Sensors)
Real-Time, Decimeter-Level Vehicle Positioning
Incorporating metrological considerations into data processing algorithms
I4S (Inférence Statistique pour la Surveillance et la Sécurité des Structures) is a joint research team between Inria and IFSTTAR.