
inLane
inLane
inLane
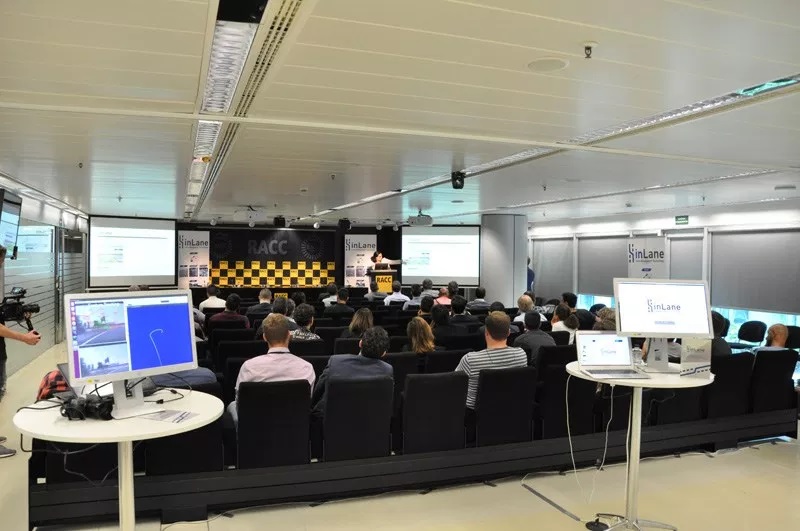
In the H2020 inLane project, as in the Espace project (which ended in 2019), IFSTTAR’s work focused on evaluating the performance of GNSS-based systems, combining satellite positioning with other exteroceptive measurements, such as camera-based vision, LiDAR and radar, as well as proprioceptive measurements, including wheel odometry and onboard inertial measurement units. The wide range of coupled technologies, particularly radio-based, photometric and, above all, inertial technologies, makes full-scale experimental testing virtually essential and makes simulation-based evaluation considerably more complex, or even significantly limited. Standardized testing procedures, designed for applications such as the accurate and safe localization of automated vehicles, still raise many open questions. An overview of the inLane project as a whole was presented in Barcelona on June 19, 2018, and at the ITS World Congress in Copenhagen on September 17, 2018, by David Bétaille (SII), focusing on performance evaluation and standardization.